
MR Clutch Actuator for a Robotic Hand
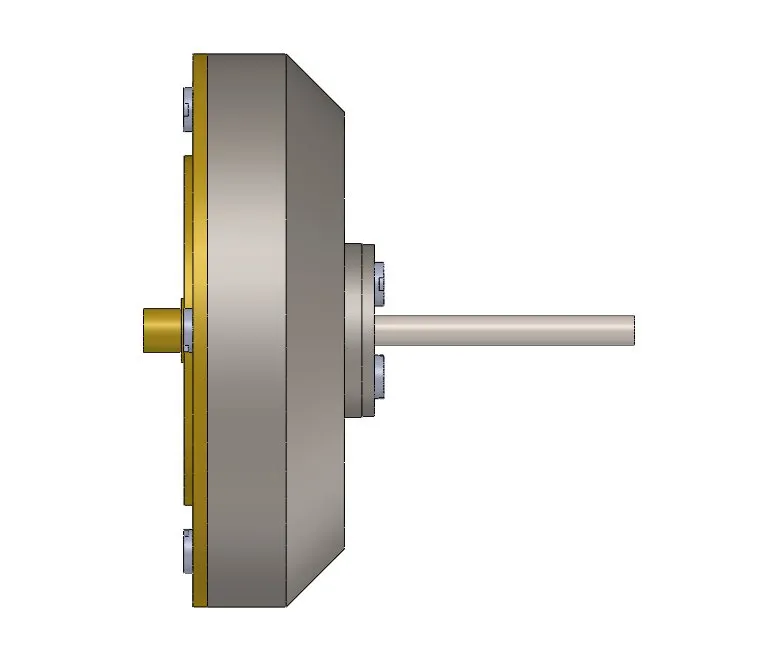
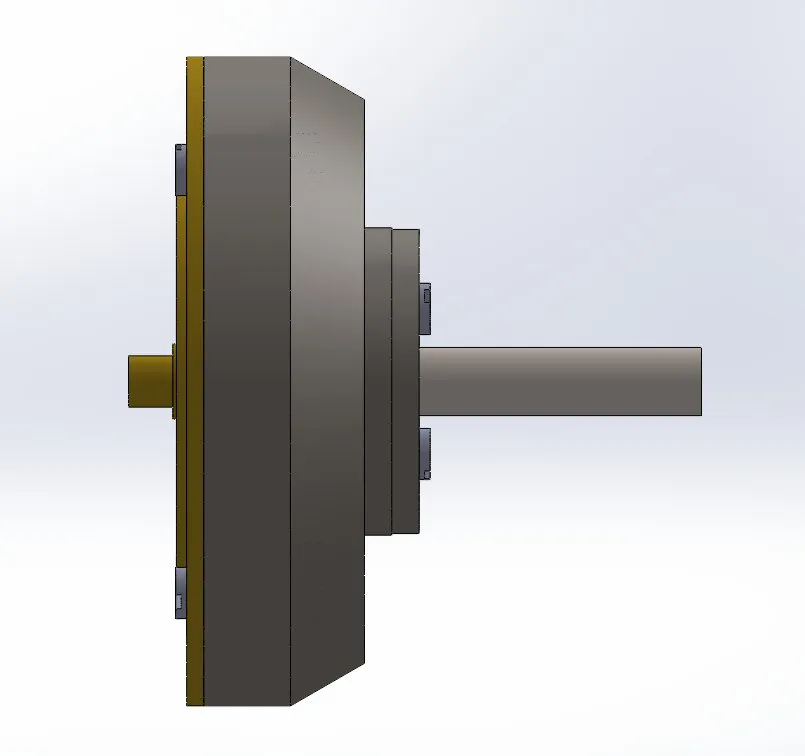
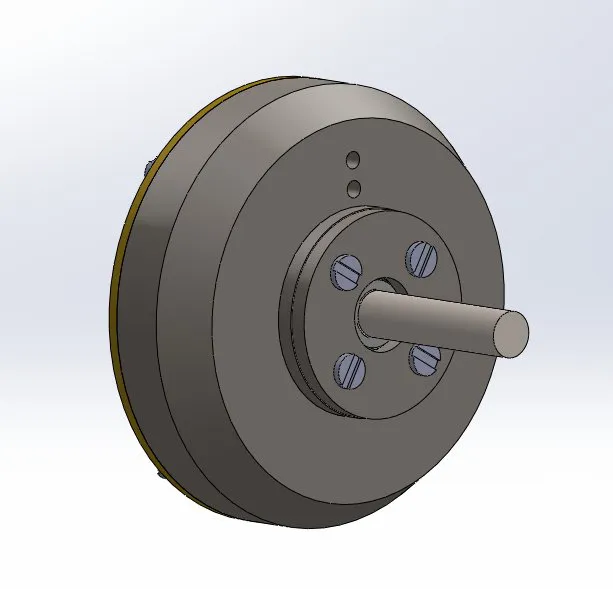
A miniaturized planetary-gear magnetorheological (MR) clutch that acts as the per-joint actuator in a fully actuated multi-finger robotic hand. MR fluid gives controllable, smooth torque transfer from a shared motor. The work builds on the squeeze-mode MR clutch concept introduced by Sergey Pisetskiy and Mehrdad R. Kermani at Western; I led the redesign that took it from a failing prototype toward fabrication.
Learn more: MR Clutch Actuator for a Robotic Hand- Sheet
- 01
- Context
- ARM Lab research
- Shaft
- Ø1 → Ø2 mm
- Coupling
- Keyway → D-profile